All application topicsDivision 1 · Robotics & Embodied AI Actuation

Robotics joint motor inquiry

Scope motor requirements for a robot joint using its load, motion profile, mechanical envelope, thermal path, feedback, and drive constraints.

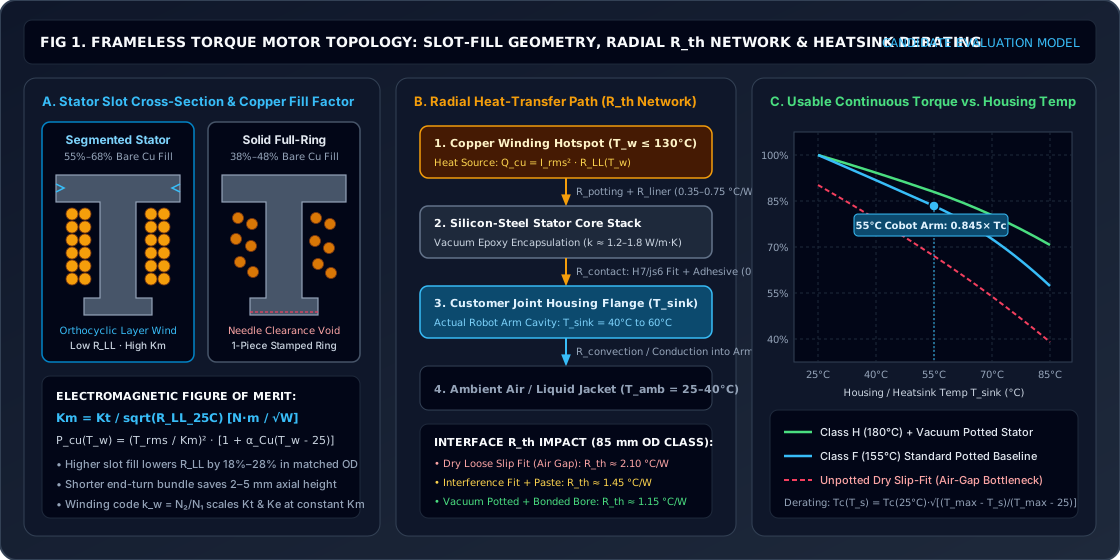
Illustrative segmented and solid stator comparison with thermal paths; not a product model or rating.

Assessment boundary

This page is an application review guide, not a product offer or performance claim. It does not confirm product availability, compatibility, energy savings, maintenance impact, certifications, supplier capacity, or delivery. These require project data and current supplier evidence.

Information to share

The following are buyer inputs for a scope review; they do not describe a standard product range.

  • Joint location (Base / Shoulder / Hip / Knee / Elbow / Wrist) and reducer type (Harmonic 50:1–100:1, Planetary QDD 6:1–15:1, or Direct 1:1)
  • Max Stator OD, Min Rotor Hollow Bore ID, and Max Axial Stack envelope (mm)
  • Continuous holding torque, peak impact/acceleration torque, and max motor input speed (RPM)
  • Battery / DC bus voltage (24V / 48V / 60V / 72V) and peak phase current limit (A_rms)
  • Target total motor kit weight (g) and annual robot production volume

Review questions

  • What load and speed profile must the motor support?
  • What mounting and mechanical changes are acceptable?
  • What thermal, environmental, and control limits apply?
  • Which supplier documents and acceptance records are required?

Frequently asked questions

Does an application page confirm a product fit or energy saving?

No. It describes information to review. Fit, product ratings, efficiency, maintenance impact, and commercial terms require project data and supplier evidence.

Is direct drive suitable for every application?

No. The load, speed range, duty cycle, mounting, thermal path, controls, service environment, and operating constraints determine whether it should be considered.

What should I provide for an application review?

Share the driven machine, load and speed data, duty cycle, interface drawings or nameplate details, operating environment, control requirements, quantity, and destination.

Related inquiry topics

Direct to PMDD Application Engineering Desk | WhatsApp: +86 188 5797 1991Division 1 · Frameless Torque Motor Inquiry

Share your target torque/speed, OD/ID or IEC frame envelope, or reference part number to initiate a project-specific engineering and RFQ scope review.

Direct Engineering Email (RFQ & CAD)

inquiry@pmddmotor.com

Submit target OD/ID, torque, and heatsink boundary conditions to confirm feasible winding constants (Kt, Kv, R_LL, L_LL, Rth) and CAD/test documentation per project.

Instant Application Engineer WhatsApp

+86 188 5797 1991

Share nameplate photos, reference part numbers (Kollmorgen / TQ / Celera), or OD/ID limits for an engineering scope review.

Global B2B Technical Inquiry Desk: Product availability, ratings, CAD files, test evidence, supplier identity, and commercial terms are confirmed per project.NDA-Ready STEP / DXF Review · Specifications & Supply Scope Confirmed per Project
Engineering Desk · +86 188 5797 1991