Hollow-Bore Rotary and Gimbal Motors: A Project Selection Checklist
Prepare a direct-drive rotary or gimbal motor inquiry with bore, load, motion profile, feedback, mounting, and thermal requirements.
This guide organizes the information needed to assess a hollow-bore direct-drive rotary axis. It does not confirm that a motor, encoder, or drive combination is available.
Describe the axis
Start with the payload and the motion it must perform. Include the load inertia, orientation, acceleration profile, travel, dwell, repeatability requirement, and any disturbance torque. If the axis moves a cable bundle, tube, or optical path through its center, include that in the bore and clearance drawing.
Separate static holding requirements from motion requirements. A motor that can hold a load at rest may still be unsuitable for the required acceleration, speed, thermal duty, or emergency stop.
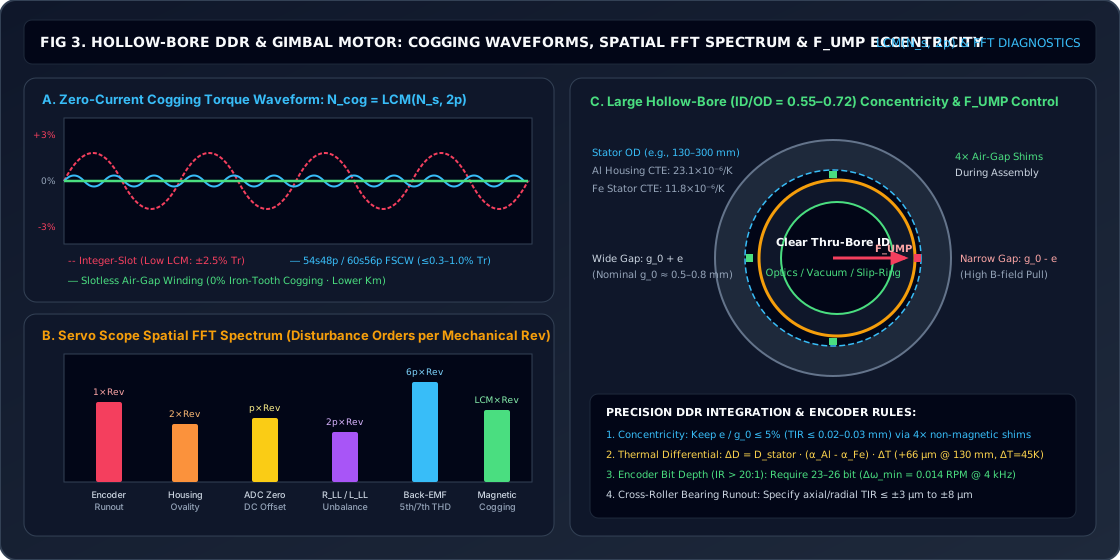
Distinguish cogging from total torque ripple
Cogging torque is a no-current effect associated with the magnetic and slot geometry. Torque ripple during operation can also come from current ripple, commutation error, encoder feedback, drive tuning, mechanical runout, and load variation.
When low-speed smoothness matters, state the test method and acceptance limit you need. A measured trace should identify the motor, fixture, angular resolution, direction, speed, temperature, drive state, and signal processing. A topology name by itself does not prove a ripple level.
Define mechanical and thermal interfaces
Provide the stator and rotor dimensions, through-bore, mounting pattern, bearing arrangement, air-gap reference, axial clearance, and installation sequence. For a frameless assembly, identify who is responsible for alignment, retention, and bearing support.
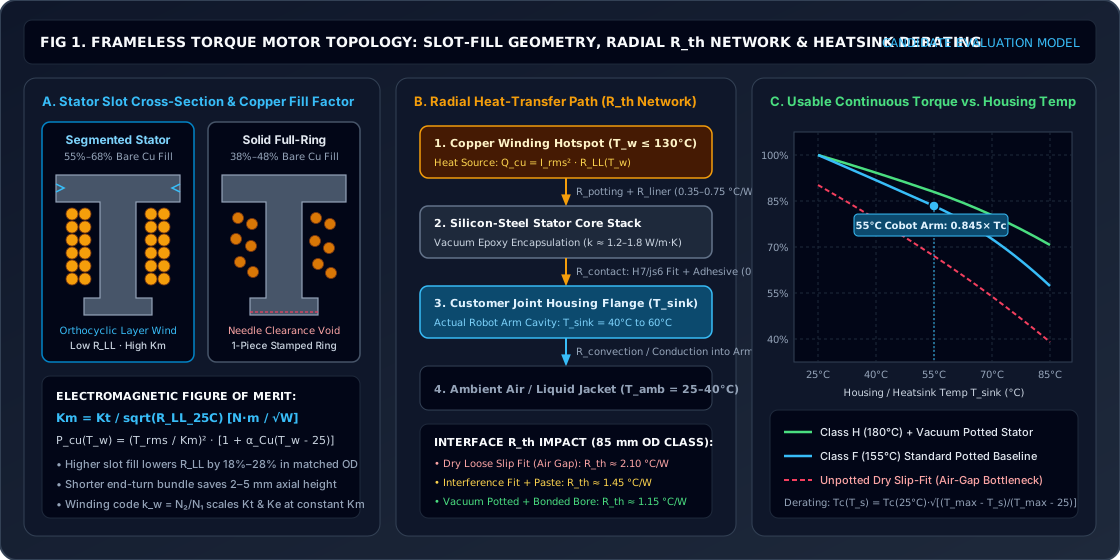
Describe the housing or cooling path, ambient conditions, nearby heat sources, and the continuous duty. Ask for model-specific ratings with their mounting and test conditions. Do not transfer thermal or runout values from a different fixture.
Plan feedback and commissioning
Specify the encoder type, resolution, electrical interface, reference or index behavior, cable routing, and servo drive model. Ask the supplier and drive vendor to confirm the supported configuration and required commissioning steps.
Do not use generic PID values or assume protocol compatibility from a product-family name. Current limits, electrical angle, pole-pair information, feedback scaling, and safety functions must match the actual motor and drive.
What to include in an RFQ
- Payload, axis orientation, inertia, motion profile, and holding duty.
- Required bore, envelope, mounting, bearing, and installation details.
- Smoothness or ripple requirement and the acceptance measurement method.
- Thermal boundary, operating environment, and duty cycle.
- Encoder, drive, controls, cabling, and safety requirements.
- Quantity, destination, required drawings, and test records.
For a possible motor alternative, send the reference model and its official interface drawing. A dimensional or electrical review is not a fit guarantee or an endorsement by the referenced manufacturer.
Share your target torque/speed, OD/ID or IEC frame envelope, or reference part number to initiate a project-specific engineering and RFQ scope review.
Direct Engineering Email (RFQ & CAD)
inquiry@pmddmotor.com
Specify required hollow-bore ID, cogging ripple ceiling, load inertia, and encoder protocol for project-specific engineering confirmation.
Instant Application Engineer WhatsApp
Share nameplate photos, reference part numbers (Kollmorgen / TQ / Celera), or OD/ID limits for an engineering scope review.
Engineering Author
Project inquiry guidance. Articles explain general methods and do not report tests on PMDD Motor or supplier products.
Engineering Categories
Prepare the operating and interface information for an application review. Requested drawings, test records, and supplier evidence are confirmed per project.
Related Engineering Guides
Frameless PM Motor Sizing: Inputs to Confirm Before a Quote
A practical RFQ checklist for frameless permanent-magnet motors: load profile, mechanical envelope, thermal mounting, winding data, and drive requirements.
Direct-Drive Retrofit Assessment: Data to Gather Before a Quote
A practical site-data checklist for evaluating a possible direct-drive retrofit of a cooling tower, mixer, conveyor, or other industrial machine.
Permanent-Magnet Generator Inquiry: Prime-Mover and Output Data
A project checklist for a permanent-magnet generator inquiry, covering the prime mover, speed range, electrical output, load, protection, and interface.
Company information
Operated by Magatom Dynamics Co., Ltd.
Legal entity and seller for new orders: Magatom Dynamics Co., Ltd..
This company signs contracts, issues commercial invoices and receives payments for new orders. Please use the payment details provided on your invoice. Supported invoice currencies: USD, EUR, JPY, GBP, CAD, AUD, SGD, HKD, CNH (Seller on contracts and commercial invoices is always Magatom Dynamics Co., Ltd.; JPY settlements use beneficiary Lianlian International Company Limited and all other supported currencies use Magatom Dynamics Co., Ltd. per the complete verified bank details on the issued commercial invoice).
Boundary notice: PMDD Motor (pmddmotor.com) is the project engineering and RFQ brand operated by Magatom Dynamics Co., Ltd.. Buyers may request Shenzhen or Dongguan as preferred sourcing regions. Actual supplier identity, manufacturing relationship, facility location, address, certifications, model ratings, equipment, and inspection protocols vary by order and are confirmed in the formal quotation and contract. No supplier facility is represented as Magatom-owned.